Release of the Physical AI Package

OnRobot Japan
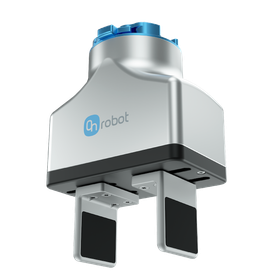
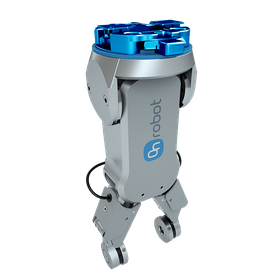
Since its founding, OnRobot has been developing electric smart grippers capable of feedback control for gripping force, position, speed, and more. To adapt to the era of physical AI, we have also prepared simulation assets such as ROS2 packages, APIs, URDF, and USD files. This enables control from ROS2, real-time control, and not only feedback of force and position data but also flexible gripping control tailored to the conditions on-site.
Related Links
We are publishing ROS2 packages, APIs, and simulation assets.